Selected projects

Mechanical systems developed for demanding applications.

Selected engineering work from Denis Vogel's industrial career, including projects completed in previous engineering and executive roles before the founding of Aenox Engineering. These examples illustrate experience across machinery, precision drives, aerospace manufacturing, mobile systems and robotics.

Selected customer and application references are shown where appropriate; additional project details remain confidential.

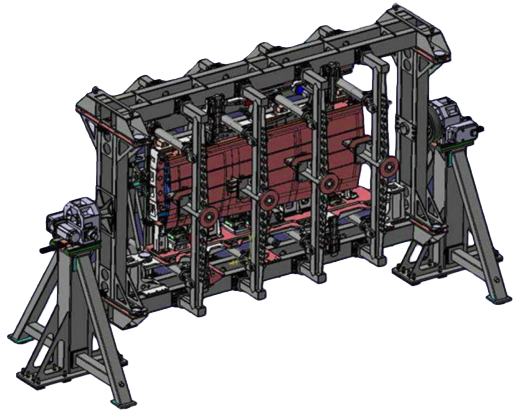
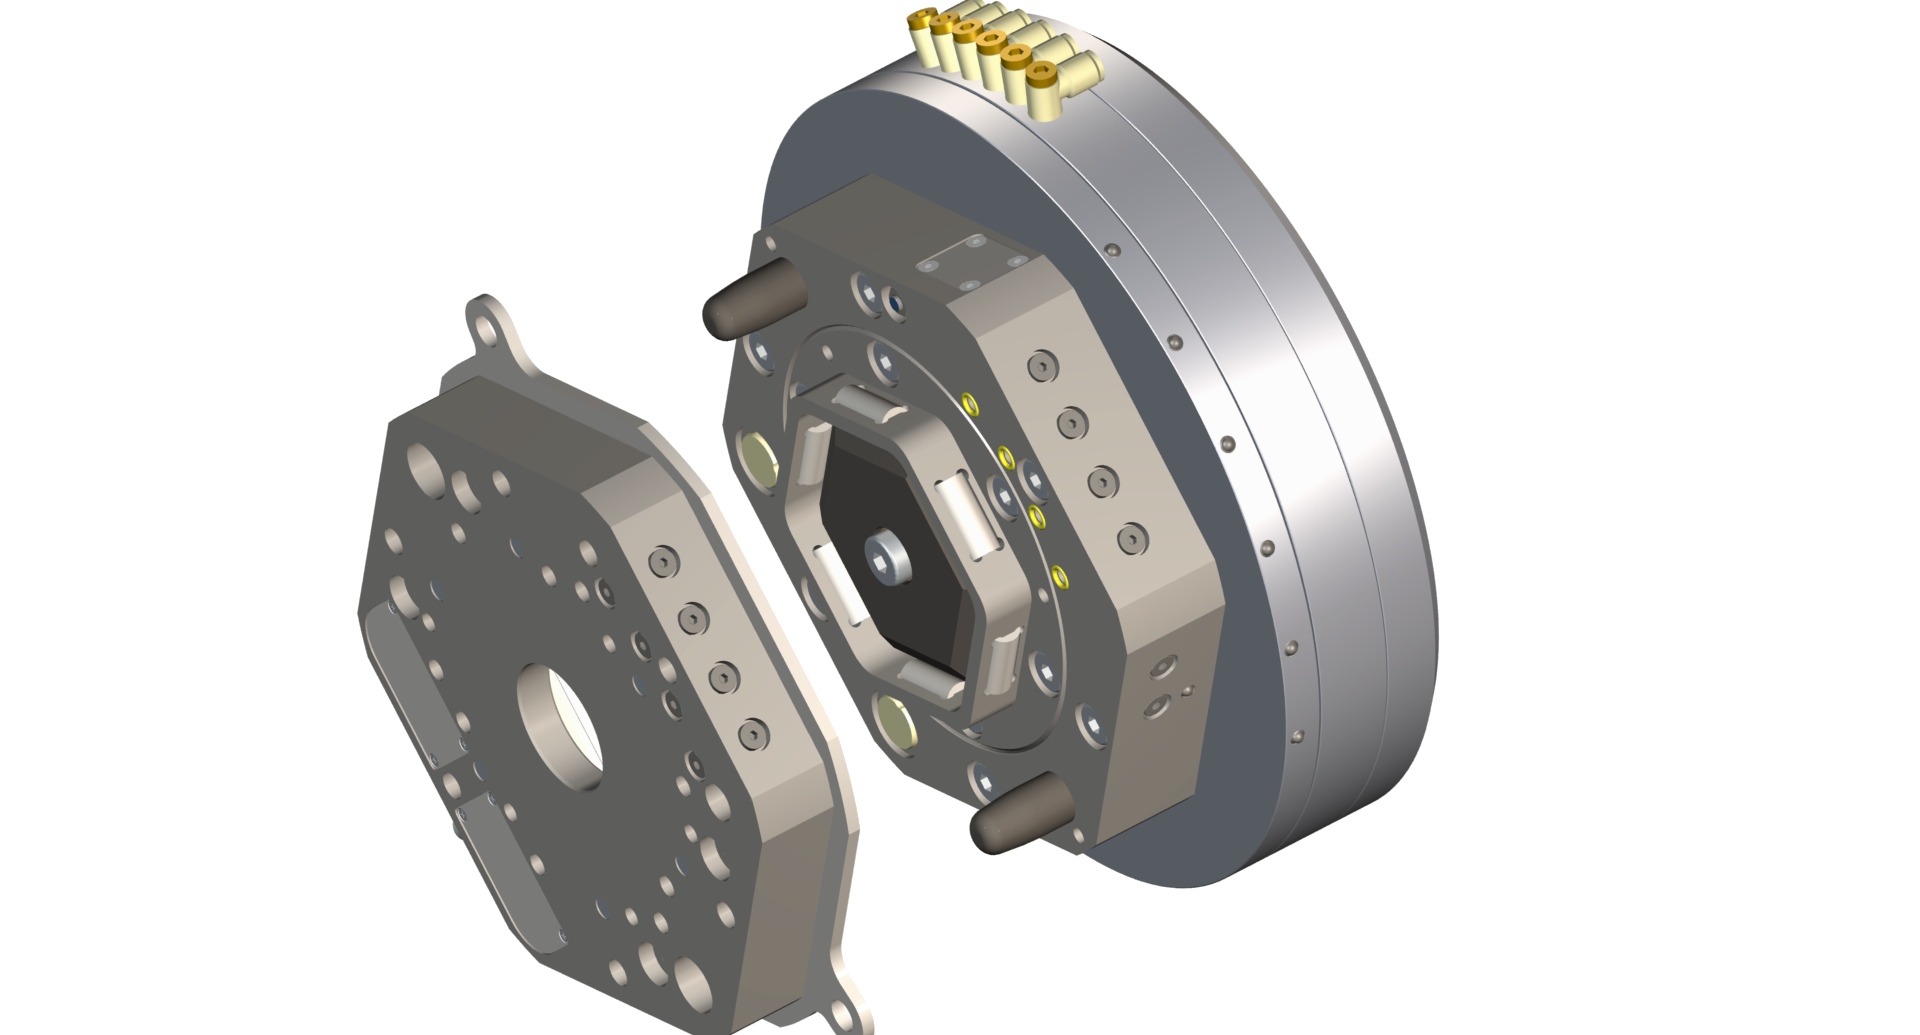
Aerospace Manufacturing Mechanism engineering reference
Work / 01

Aerospace Manufacturing Mechanism

Development of a high-precision mechanical system for aerospace manufacturing, with focus on stiffness, positioning accuracy, drivetrain architecture, manufacturability and integration into the production environment.

AerospacePrecision EngineeringMechanical SystemsDrive Engineering
Project details →
Custom Manufacturing Equipment engineering reference 1
Work / 02

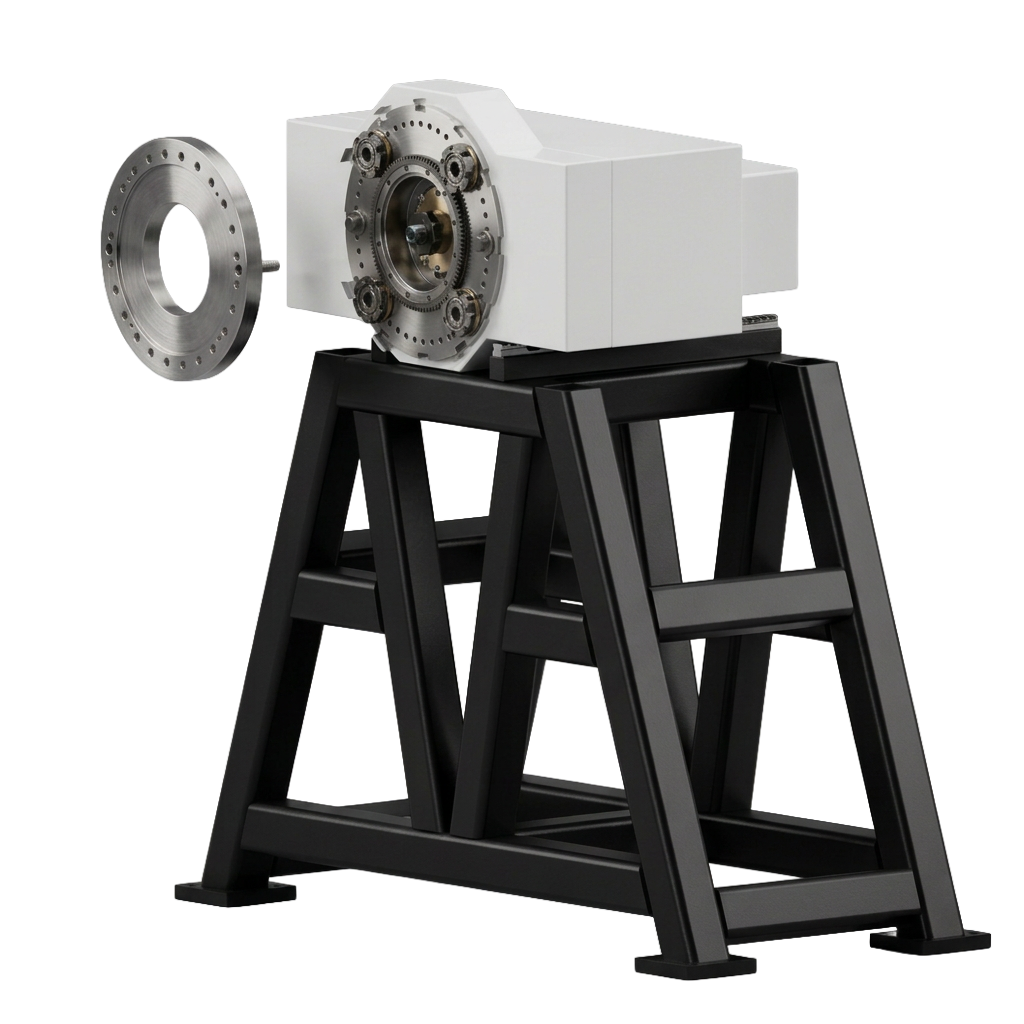
Custom Manufacturing Equipment

Mechanical concept and detailed engineering of customer-specific production equipment — from load cases and machine architecture through CAD, structural verification, manufacturing design and industrialisation.

Special MachineryMechanical EngineeringIndustrialisation
Project details →
High-Torque Rotary Axis engineering reference
Work / 03

High-Torque Rotary Axis

Development of a high-stiffness rotary positioning system with direct feedback including bearing architecture, drivetrain concept, zero-clamp, servo integration and structural verification for demanding static and dynamic loads.

32 kNm torque · 10 arcsec repeatability

DrivetrainPrecision MechanicsRotary AxesServo Systems
Project details →
Robotic Manufacturing Systems engineering reference 1
Work / 04

Robotic Manufacturing Systems

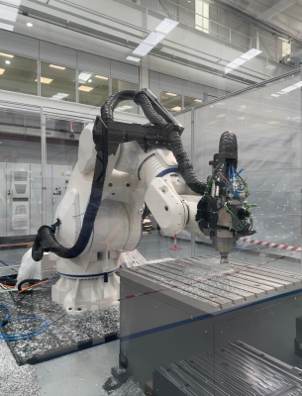
Development of high-stiffness robotic manufacturing systems for machining and advanced production processes. Engineering scope included concepts, mechanical architecture, peripheral axes, tooling, metrology, process equipment and industrial integration.

0.15 mm path accuracy in steel machining · parts up to 20 m

RoboticsCNC MachiningAdvanced ManufacturingAerospaceLarge-Part Manufacturing
Project details →
Automated Guided Vehicle Systems engineering reference 1
Work / 05

Automated Guided Vehicle Systems

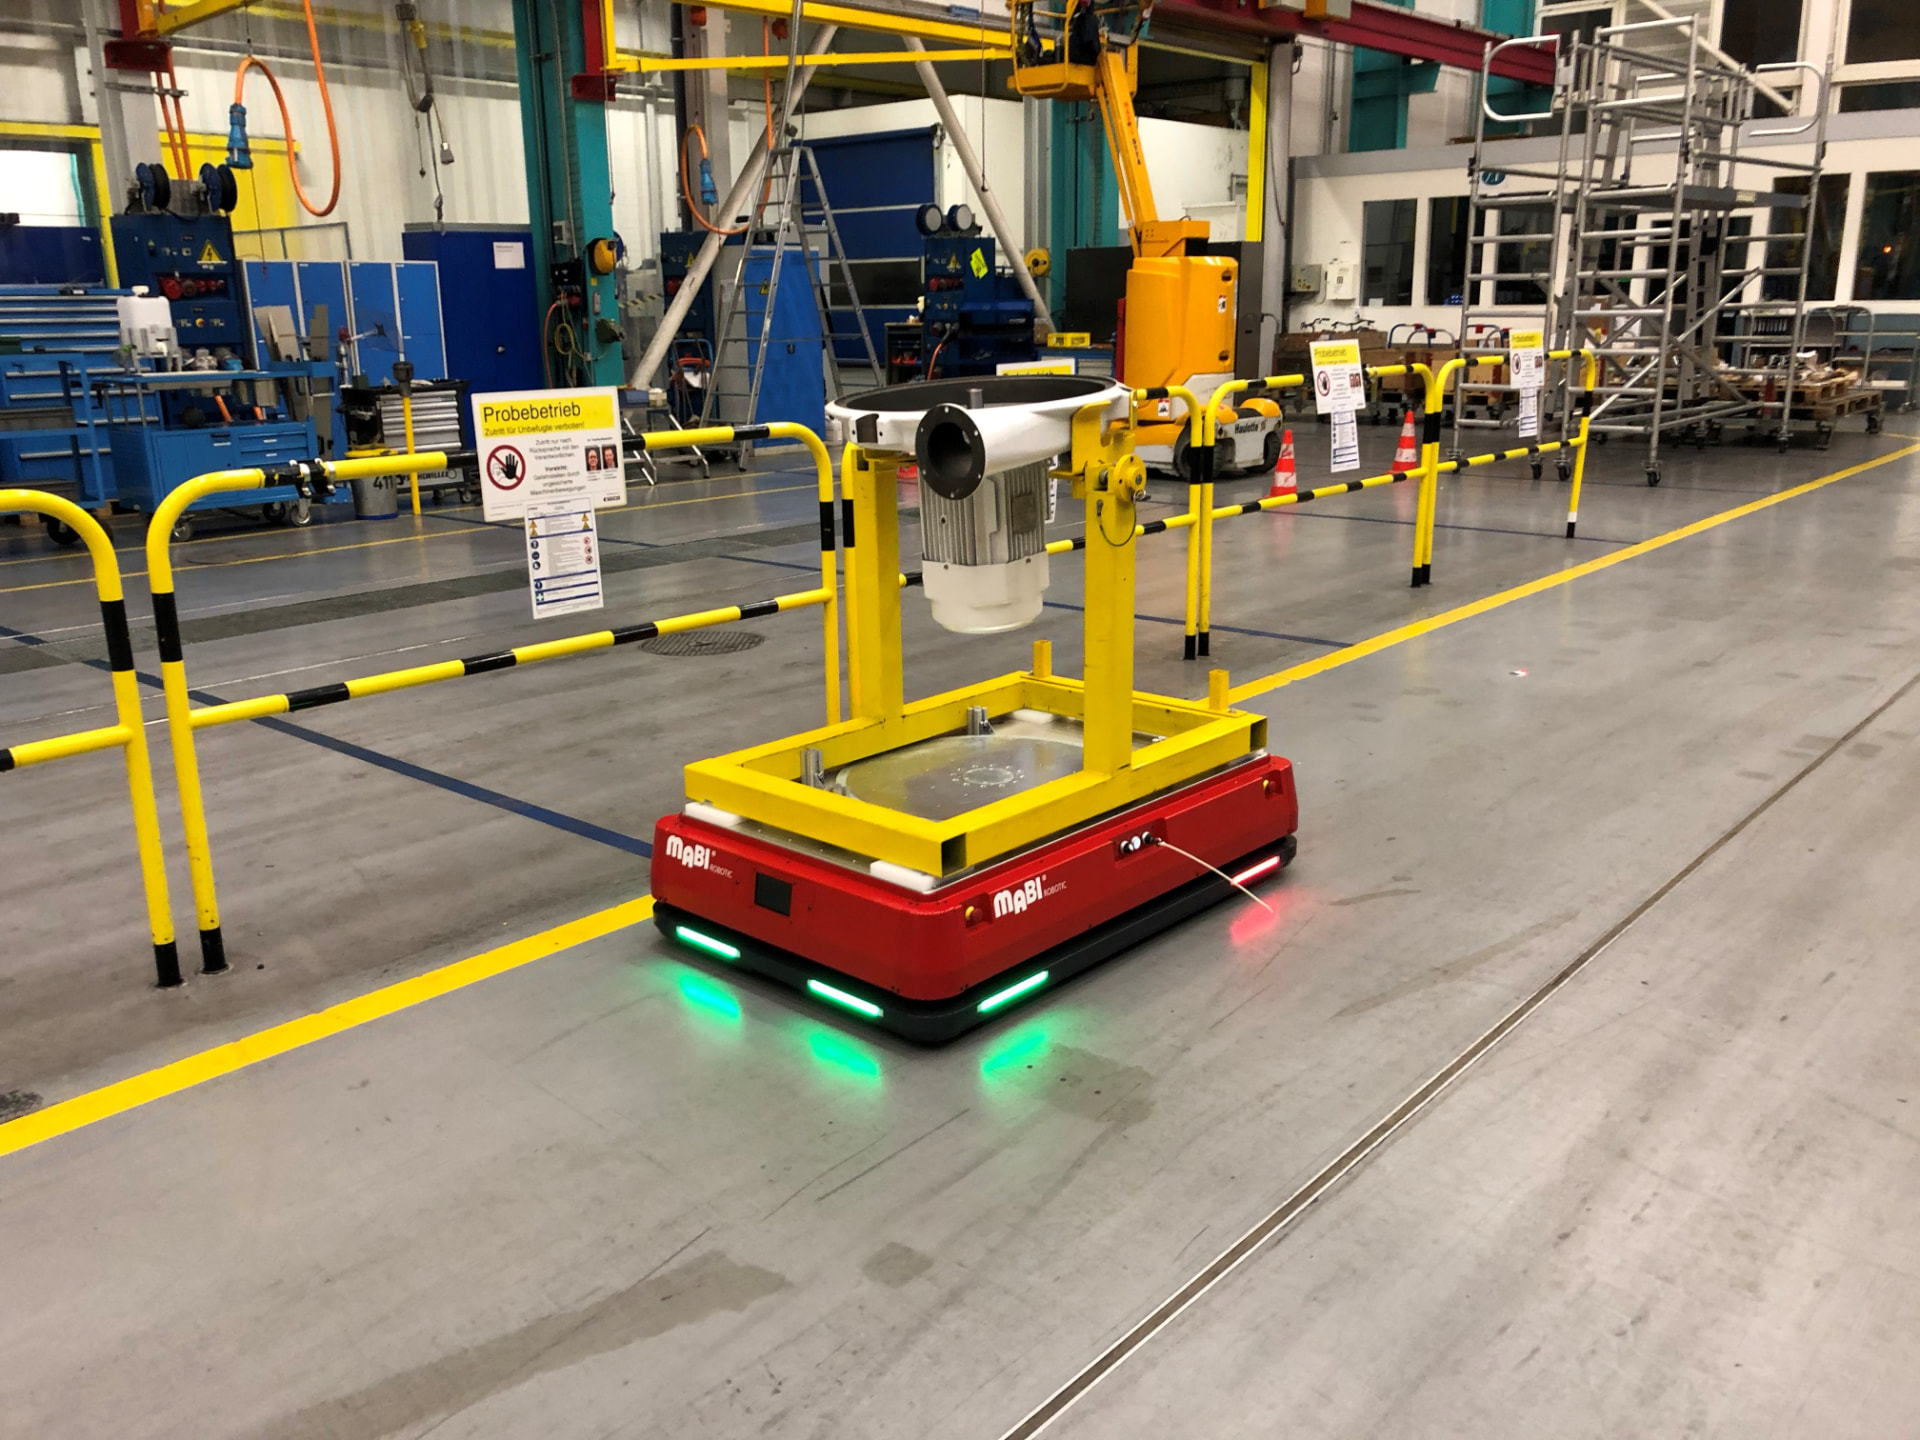
Development of mobile, semi-autonomous and autonomous industrial platforms for material handling and assembly applications. Engineering included mechanical architecture, modular payload interfaces, sensor integration, drive systems and customer-specific tooling.

5000 kg payload

AGVAMRMobile RoboticsAutomationAutomotive
Project details →
Robot Track Systems engineering reference 1
Work / 06

Robot Track Systems

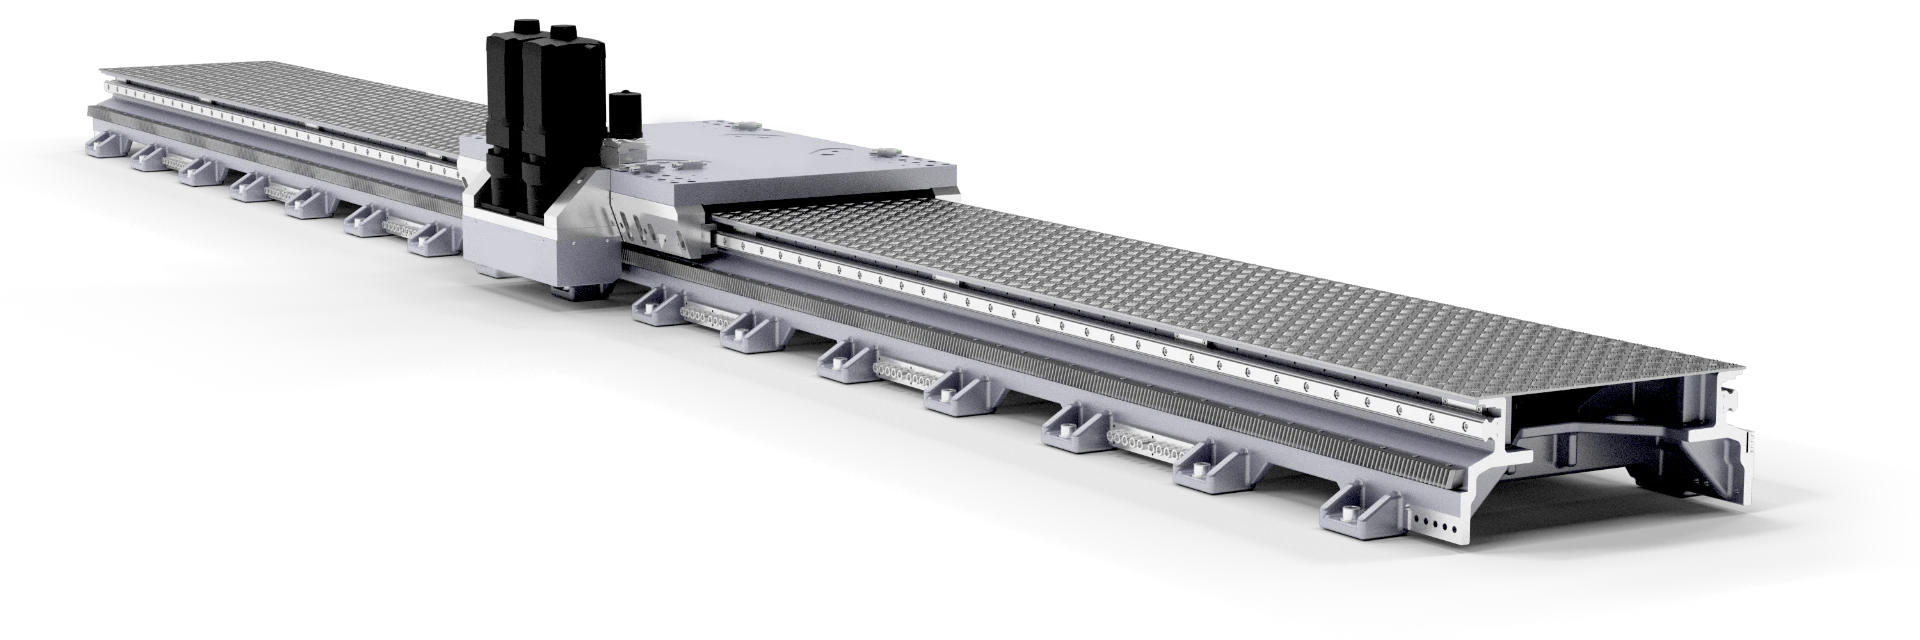
Development of high-stiffness, backlash-minimised linear positioning axes for industrial robots and multi-axis manufacturing systems. Engineering focus included structural stiffness, positioning accuracy, long travel, drivetrain architecture and integrated cable management.

Linear AxesRoboticsPrecision EngineeringDrive Systems
Project details →
Two-Axis Manipulators engineering reference 1
Work / 07

Two-Axis Manipulators

Development of compact two-axis positioning systems for handling, welding and assembly applications. Gearbox-driven and direct-drive architectures were developed depending on payload, dynamics and precision requirements. Engineering included bearings, drivetrain architecture, feedback systems and mechanical integration.

1000 kg payload · 5 arcsec repeatability

ManipulatorsPositioning SystemsGearbox TechnologyDirect Drive
Project details →
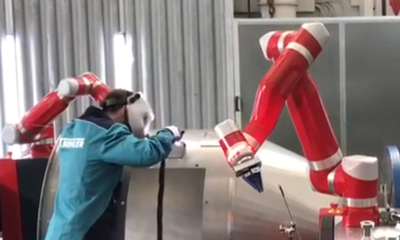
Collaborative Lightweight Robot Systems engineering reference
Work / 08

Collaborative Lightweight Robot Systems

Development of collaborative six-axis robot systems with lightweight mechanical structures, joint torque sensing and functional-safety architecture for human-robot collaboration. Engineering included thin-wall cast components, mechanical architecture, static and dynamic FEA, drivetrain integration and industrialisation.

15 kg payload · 30 kg robot mass · PL d / Cat. 3

Collaborative RoboticsLightweight DesignFunctional SafetySix-Axis Robotics
Project details →
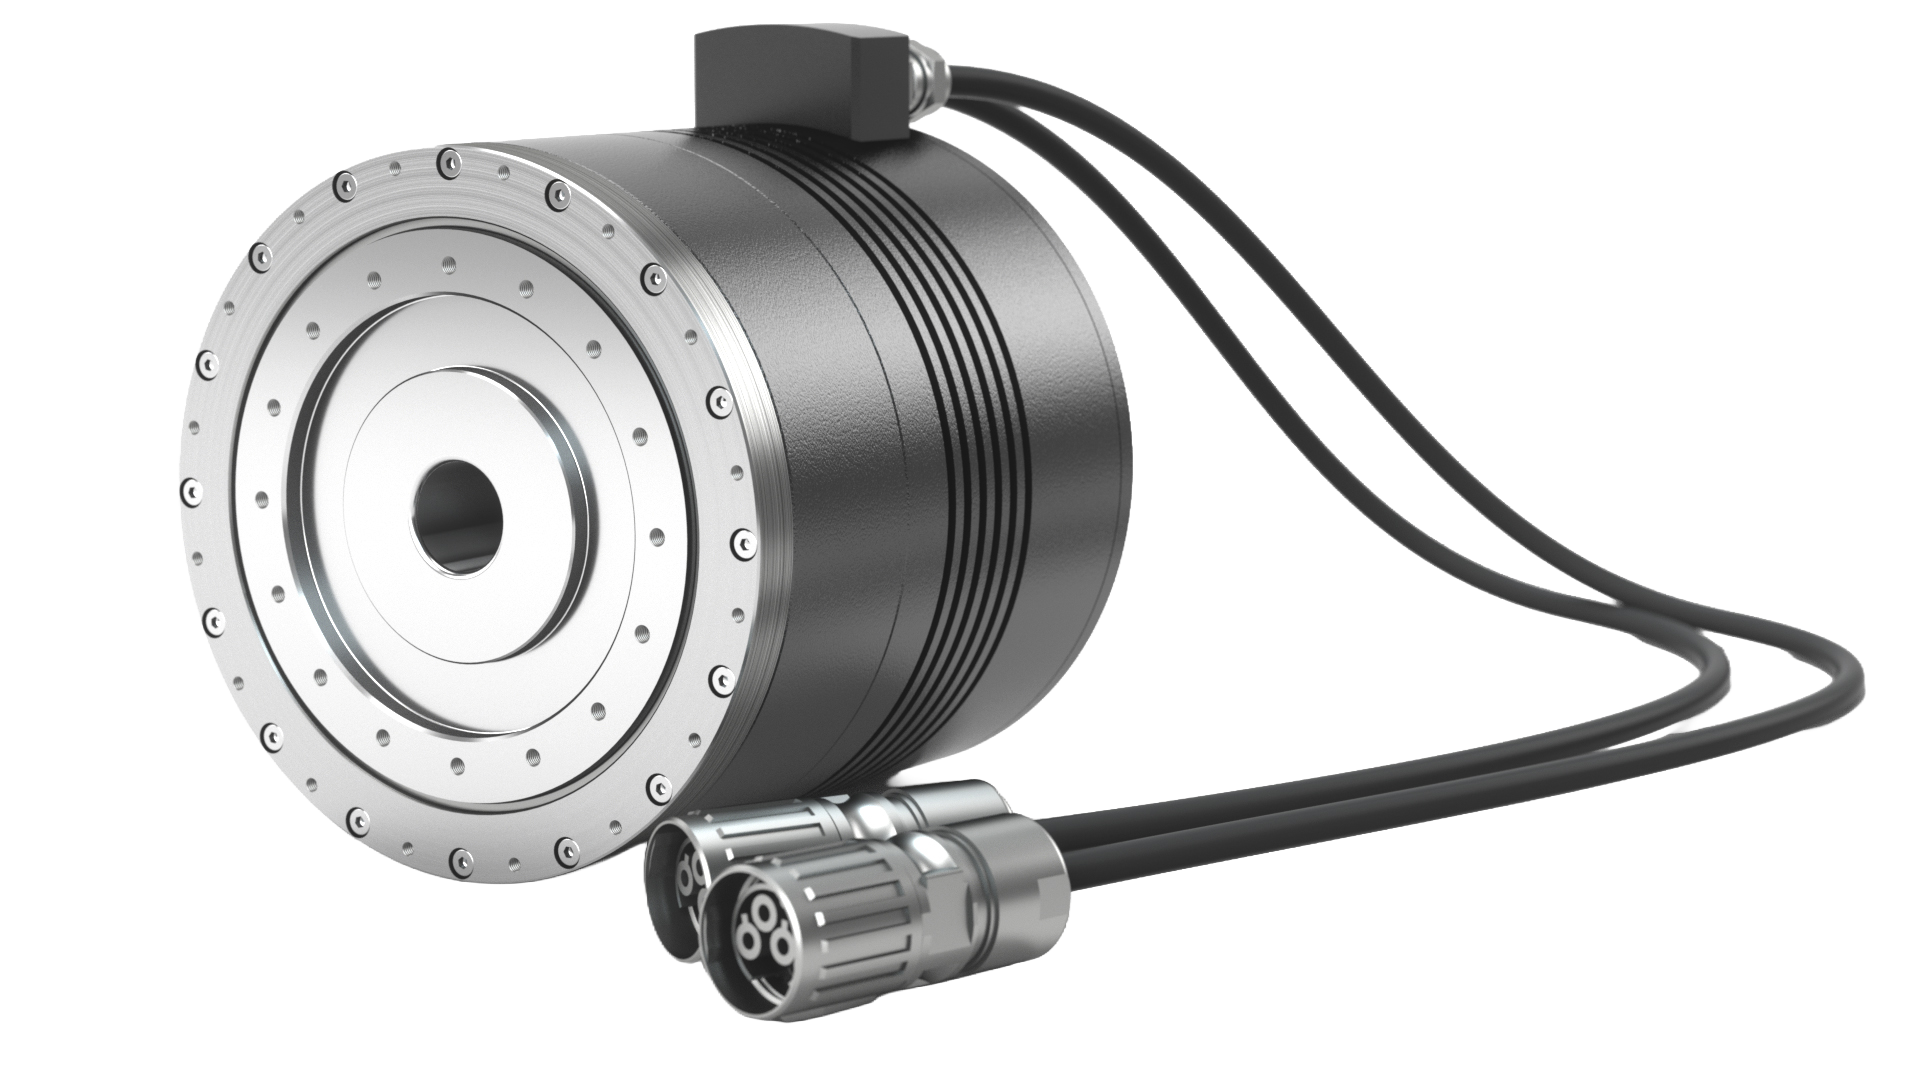
Electric Motor Development engineering reference 1
Work / 09

Electric Motor Development

Development of compact electric motors for integration into drive systems — hollow-shaft and shaft-output variants. Engineering included mechanical motor architecture, housing and flange design, bearing arrangement, thermal design of the housing, feedback and cable integration.

Electric MotorsDrive SystemsMechanical DesignHollow Shaft
Project details →
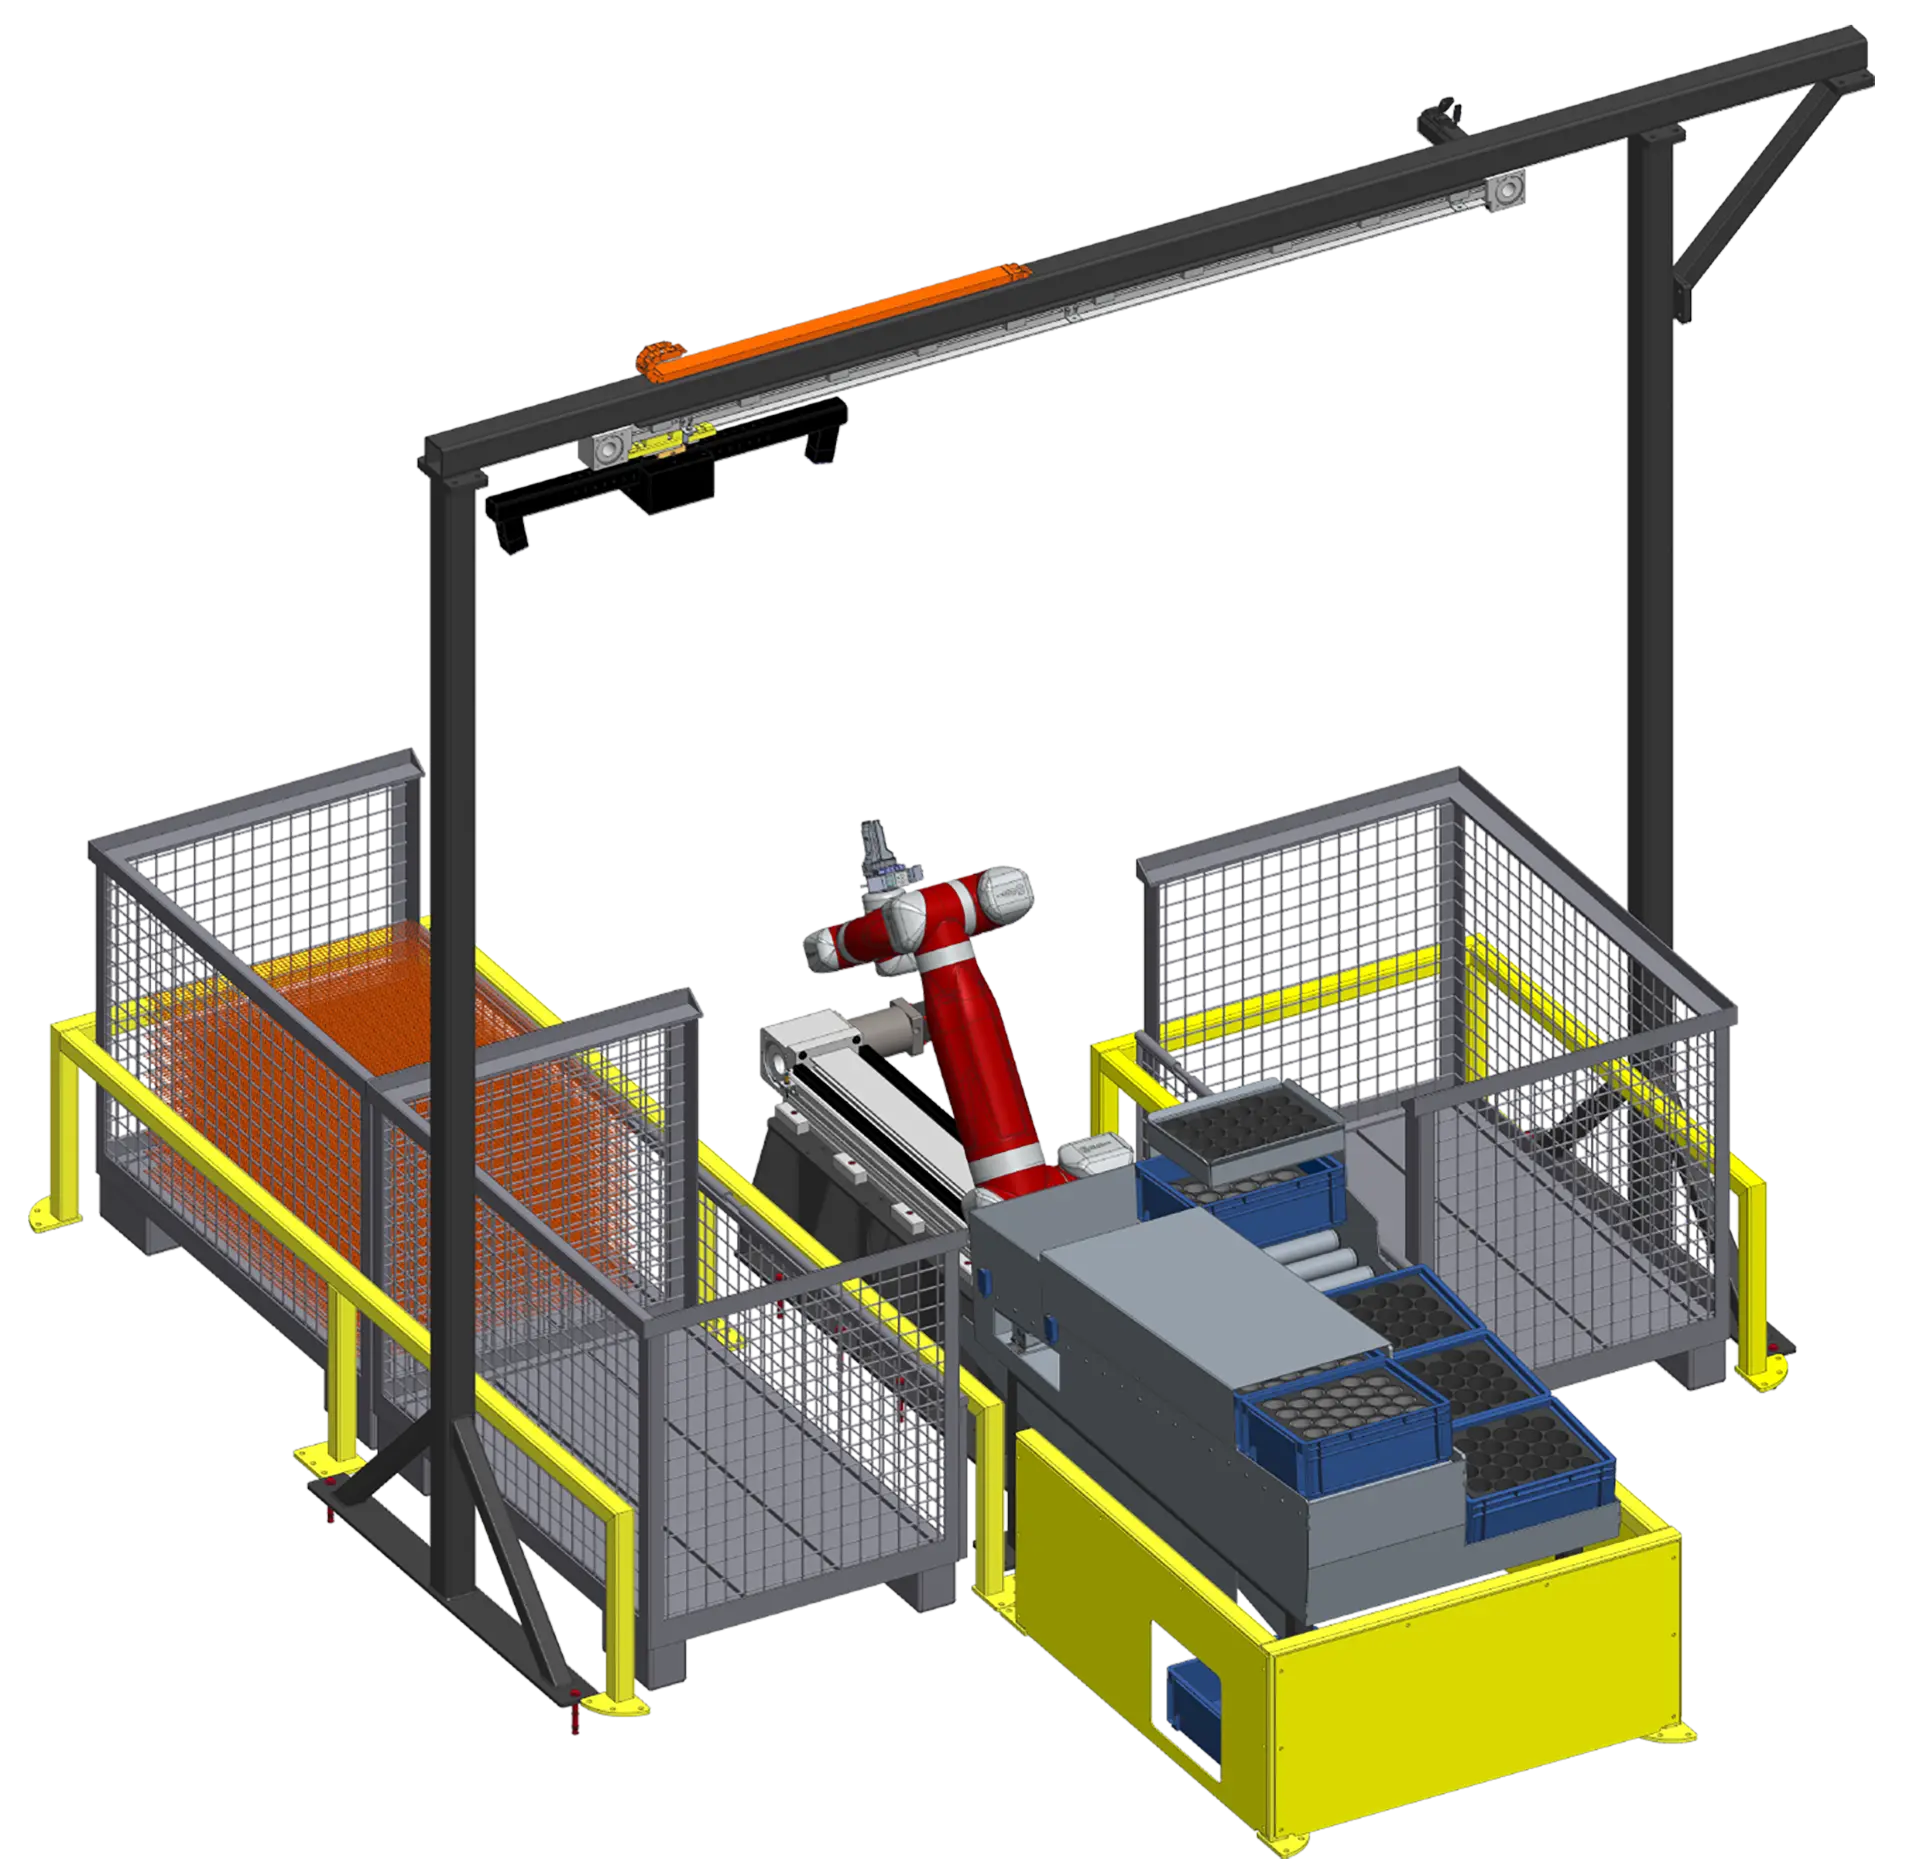
Automation Projects engineering reference 1
Work / 10

Automation Projects

Concept and detailed engineering of a robotic automation cell for material handling with vision system — including robot integration, cell structure and guarding, workpiece container logistics and conveyor interface.

AutomationRoboticsMaterial HandlingCell Design
Project details →
Current reference
GKN Aerospace
Engineering experience with
AirbusSiemens EnergyBlue OriginVolkswagenMitsubishi Heavy IndustriesFivesZEISSBMW MotorradGKN Aerospace

Experience from earlier engineering and executive roles.

Project references may include engineering work performed by Denis Vogel in previous professional roles and do not necessarily represent contracts executed by Aenox Drive AG.

Start a conversation

Have a challenging engineering problem?

Discuss your project